Project archive
Projects built across robotics, autonomy, and control.
A complete archive of research and engineering work, with methods, tools, and documented outcomes.
 View case study →
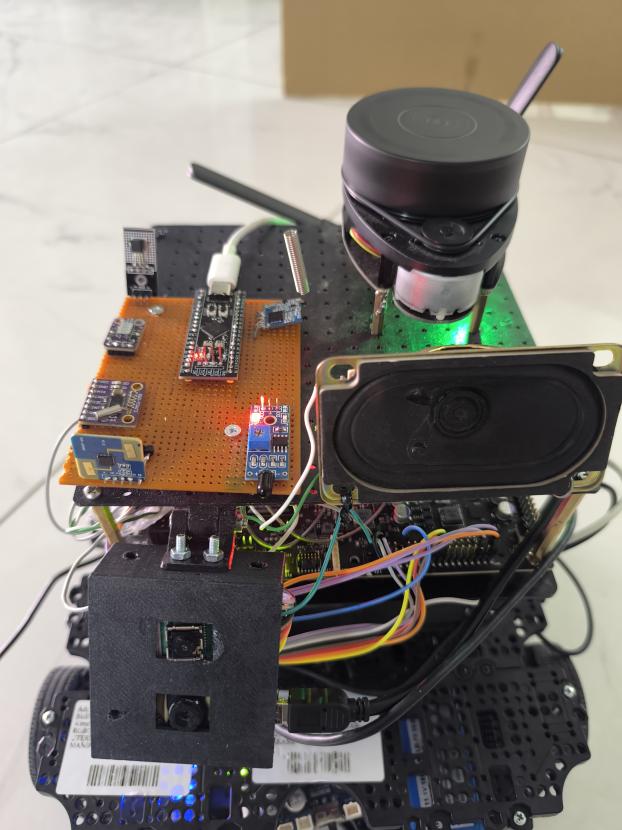
Offline AI Payload for Search & Rescue Robots
A modular payload for rescue robots that combines thermal and visual detection, a radar sensor, gas and flame sensing, an offline voice assistant and long-range alerts, all running on a small Jetson TX2 computer without internet.
 View case study →
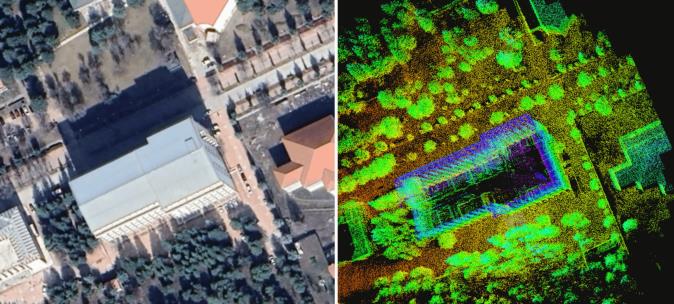
Demonstrating the Efficiency of RKO-LIO on a DJI UAV Platform Utilizing Drone Built-in IMU for GPS-Denied Mapping
A mapping payload for the DJI Matrice M350 RTK drone that builds accurate 3D maps of outdoor areas without relying on GPS. A LiDAR scanner and a small onboard computer reuse the drone's built-in motion sensor, so no extra sensor is needed.
 View case study →
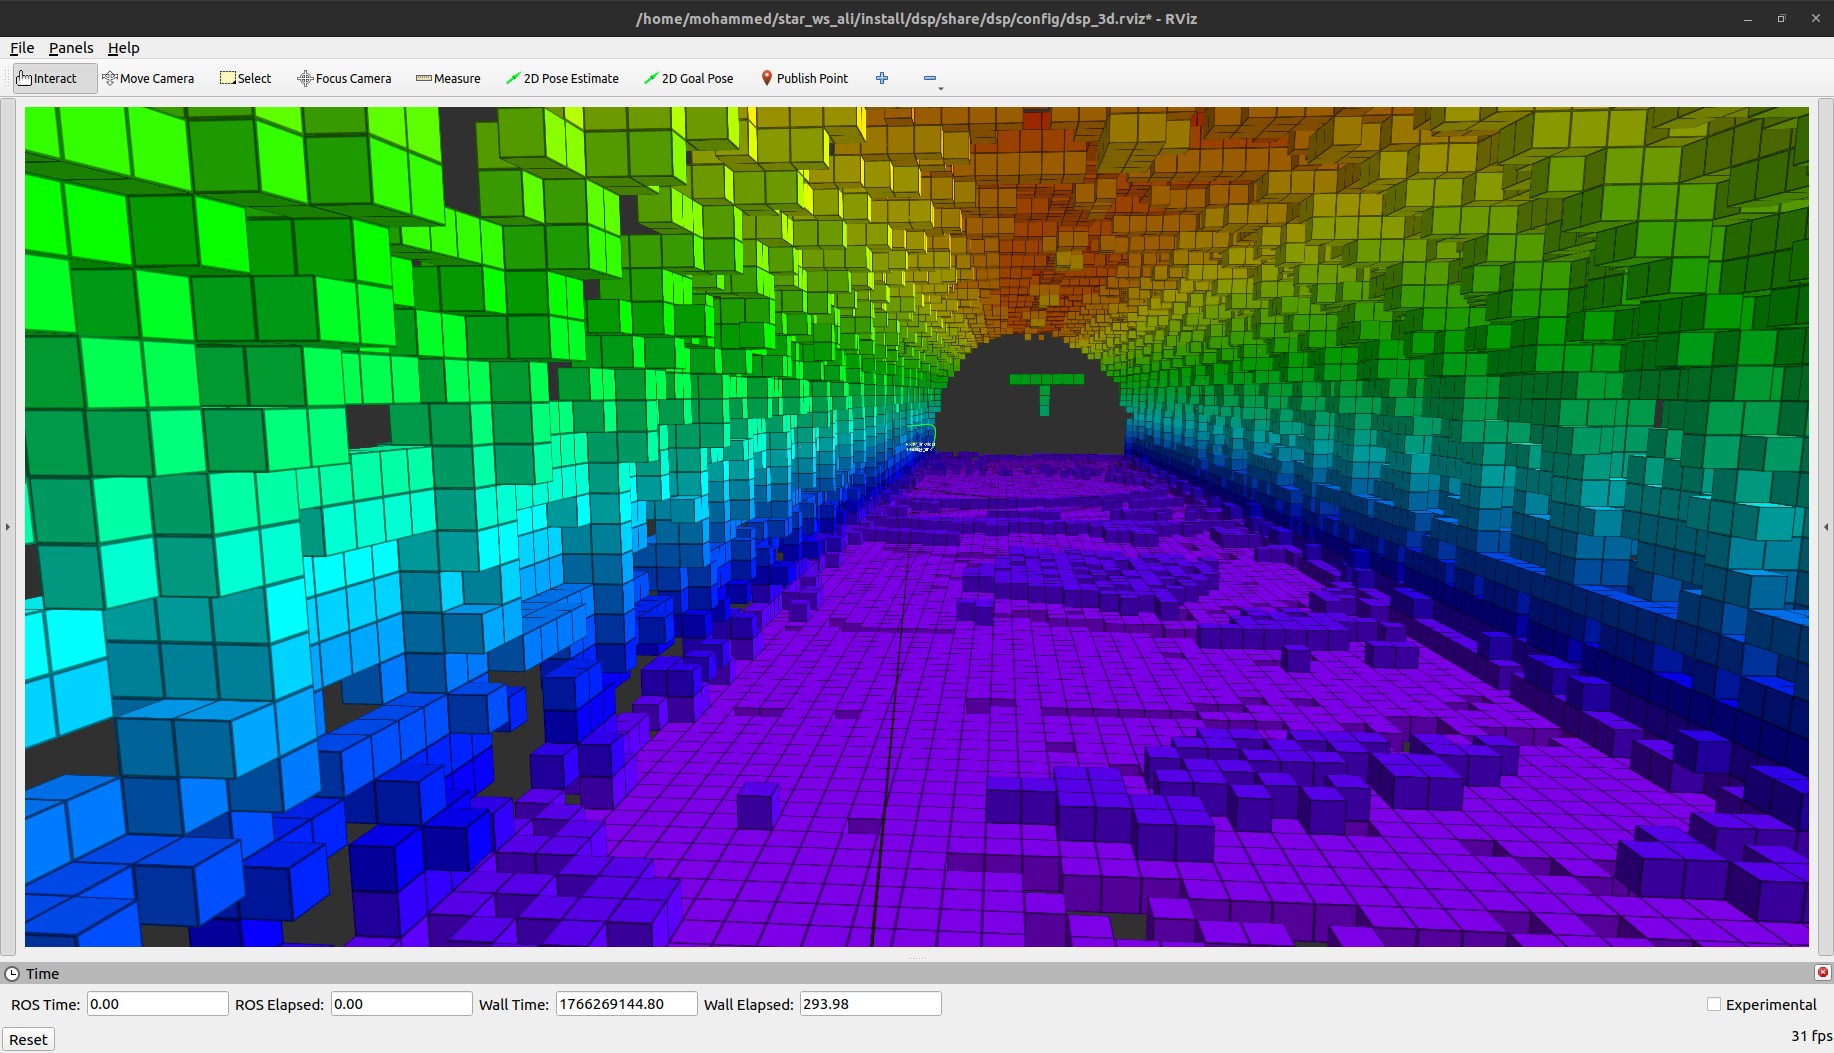
Autonomous Cave Exploration & Obstacle-Avoidance Drone
A simulated drone that explores caves, tunnels and mines without GPS. It builds a live 3D map from a LiDAR, plans collision-free routes through it, picks its own next target and recovers when it gets stuck.
 View case study →
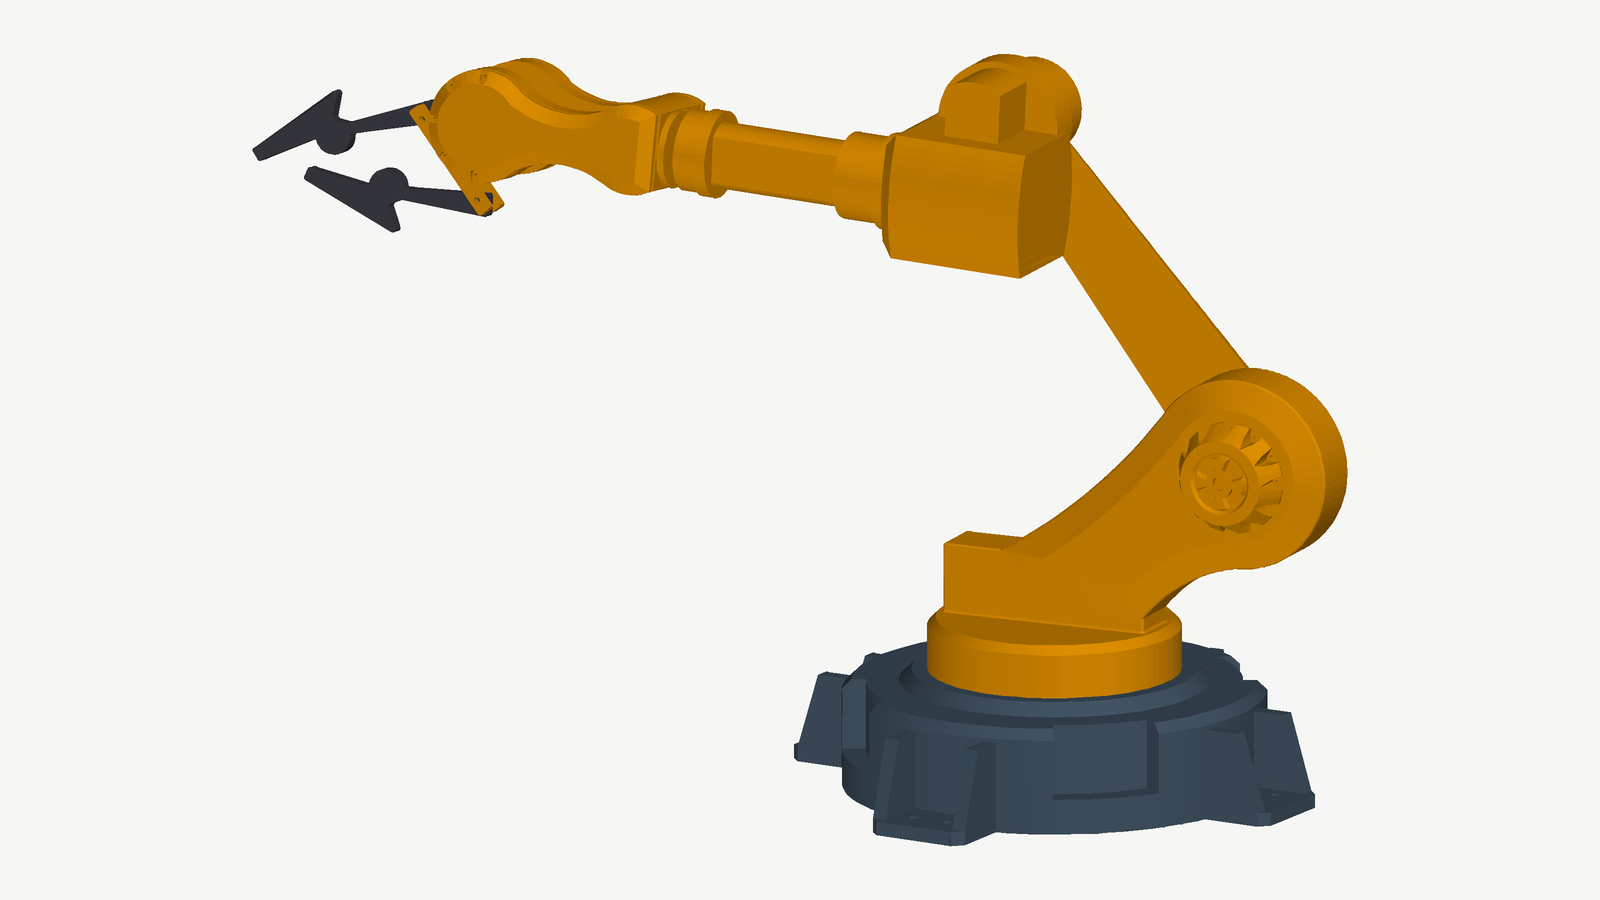
Robotic Arm: SolidWorks Design to Simscape Control
A robotic arm taken from CAD design to physics simulation. SolidWorks models are imported into Simscape Multibody, inverse kinematics turn a target point into joint angles, and PID control is demonstrated on a simpler two-joint version.
 View case study →
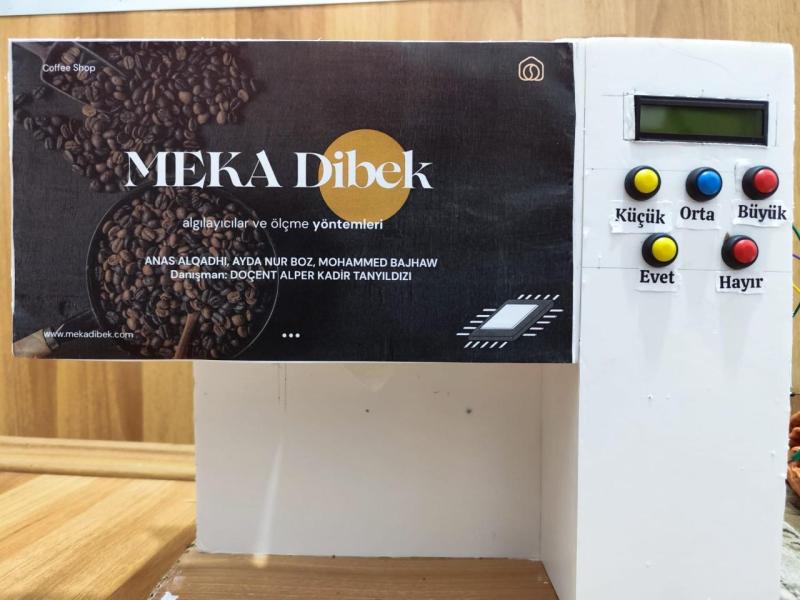
Automated Coffee Preparation System
An embedded automation prototype that coordinates preparation stages from a Raspberry Pi control core. Modular Python software, relay-switched loads, PWM servo actuation, and a local LCD/keypad interface were brought together to automate ingredient dispensing, pumping, and heating-related control.
 View case study →
CNC Multi-Function Conversion System
A multi-function digital-fabrication platform created by converting a 3D printer into an interchangeable-tool CNC system. The documented workflow combines mechanical redesign, SVG-to-G-code preparation, and material-aware calibration for wood carving, plastic engraving, and 2D drawing.